2027
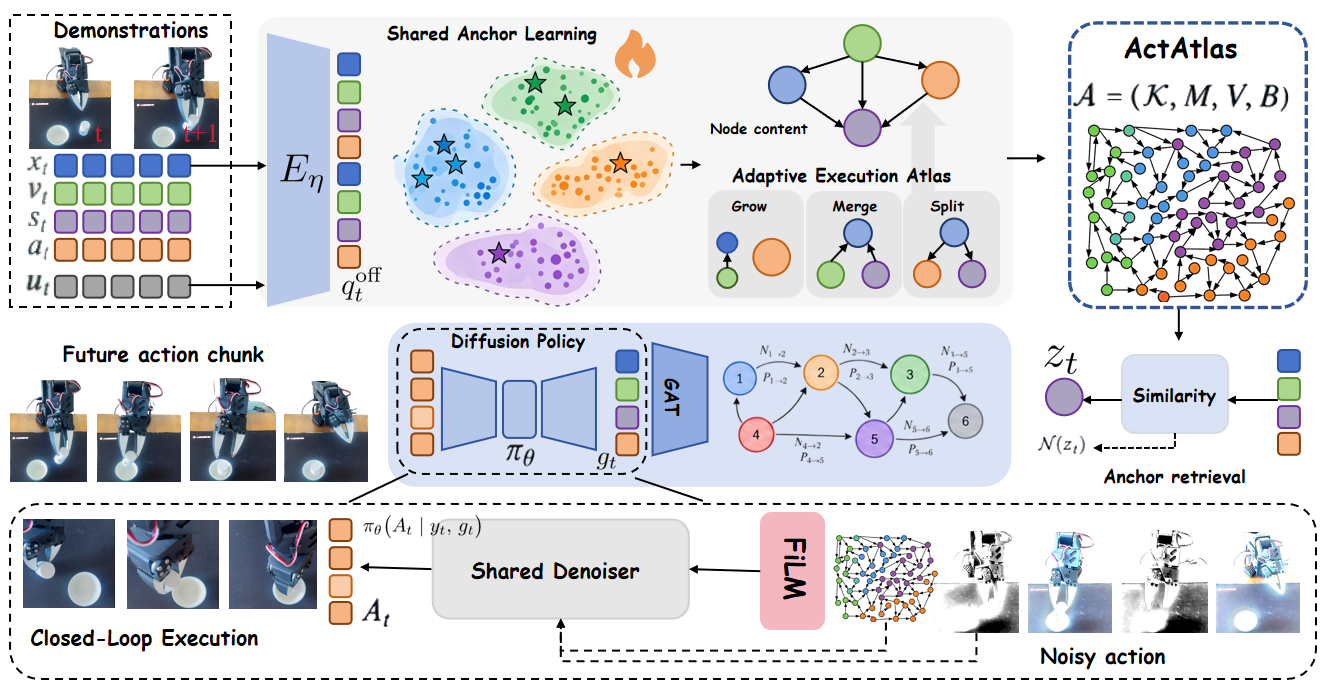
ActAtlas: Learning Adaptive Execution Atlases for Long-Horizon Robot Manipulation Robotics
Haidong Huang*, Yutong Shen*, Heng Zhang, Xingwei Chen, Haiyue Zhu, Jun Ma, Ding Zhao, Xiaocong Li (* equal contribution)
SubmissionUnder review. 2027
We proposes an imitation‑learning framework that obtains adaptive execution anchors via self‑supervised learning to construct an execution‑flow graph, and conditions a diffusion policy with this graph to address the challenge where locally similar states demand distinct actions under different contexts in long‑horizon robotic manipulation tasks, achieving superior performance across multiple simulation benchmarks.
ActAtlas: Learning Adaptive Execution Atlases for Long-Horizon Robot Manipulation Robotics
Haidong Huang*, Yutong Shen*, Heng Zhang, Xingwei Chen, Haiyue Zhu, Jun Ma, Ding Zhao, Xiaocong Li (* equal contribution)
SubmissionUnder review. 2027
We proposes an imitation‑learning framework that obtains adaptive execution anchors via self‑supervised learning to construct an execution‑flow graph, and conditions a diffusion policy with this graph to address the challenge where locally similar states demand distinct actions under different contexts in long‑horizon robotic manipulation tasks, achieving superior performance across multiple simulation benchmarks.
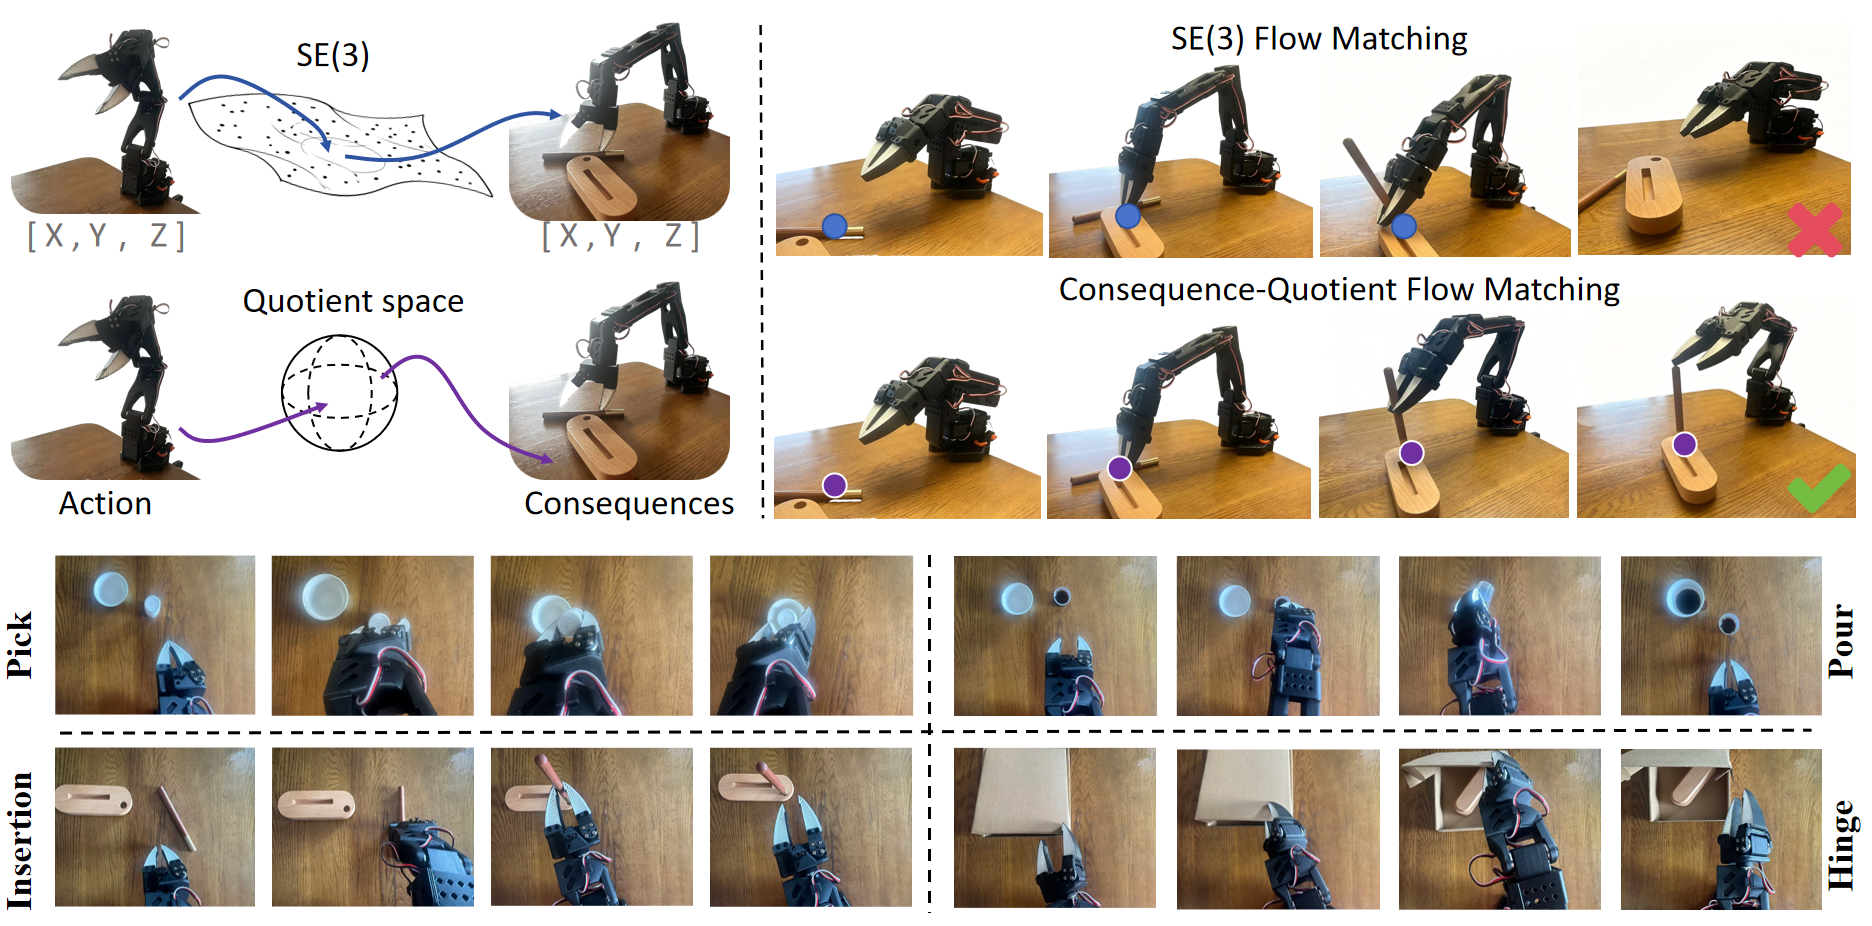
Consequence-Quotient Flow Matching for Robot Manipulation Robotics
Yutong Shen*, Haidong Huang*, Haoxuan Xu, Heng Zhang, Yiqing Yin, Lei Zhang, Xiaocong Li (* equal contribution)
SubmissionUnder review. 2027
We propose CQ‑FM, which constructs a consequence‑quotient space based on task outcomes, pulls back the consequence‑aware metric into the action space via Jacobians, reshapes the Flow‑Matching loss during training and enables closed‑loop correction at inference to improve the task success rate and contact stability of vision‑language‑action robot manipulation policies.
Consequence-Quotient Flow Matching for Robot Manipulation Robotics
Yutong Shen*, Haidong Huang*, Haoxuan Xu, Heng Zhang, Yiqing Yin, Lei Zhang, Xiaocong Li (* equal contribution)
SubmissionUnder review. 2027
We propose CQ‑FM, which constructs a consequence‑quotient space based on task outcomes, pulls back the consequence‑aware metric into the action space via Jacobians, reshapes the Flow‑Matching loss during training and enables closed‑loop correction at inference to improve the task success rate and contact stability of vision‑language‑action robot manipulation policies.
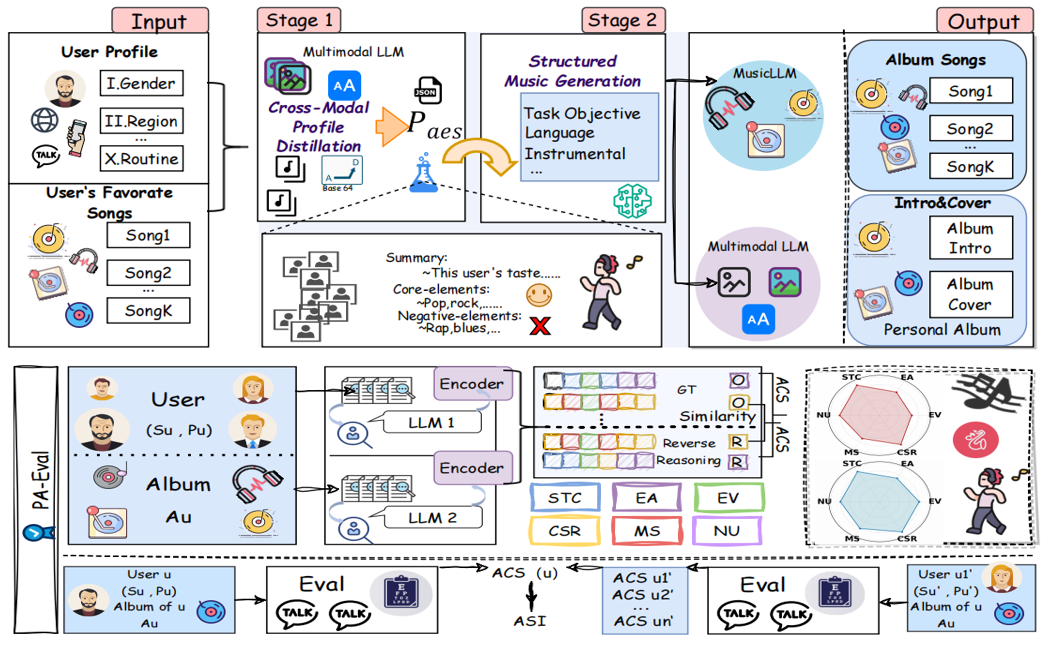
Anchoring Personal Aesthetics in Music Generation through Cross-Modal Distillation and Automated Six-Dimensional Evaluation Multimodal
Yifeng Mao, Ziye Wang, Feiran Liu, Yi Shan, Runhao Quan, Ang Li, Renzhao Liang, Yuzhe Zhang, Yutong Shen, Wenjuan Han
The Annual Conference of the European Chapter of the Association for Computational Linguistics (EACL)Under review. 2027
This paper proposes the zero-shot multimodal PAG-Agent framework for personalized music album generation with cross-modal aesthetic distillation, builds the ethical Personal-100 dataset, and designs the PA-Eval benchmark equipped with ACS and ASI metrics to quantify subjective aesthetic alignment, whose experiments show it surpasses all baselines with significant gains in aesthetic consistency and specificity and is validated by human evaluations.
Anchoring Personal Aesthetics in Music Generation through Cross-Modal Distillation and Automated Six-Dimensional Evaluation Multimodal
Yifeng Mao, Ziye Wang, Feiran Liu, Yi Shan, Runhao Quan, Ang Li, Renzhao Liang, Yuzhe Zhang, Yutong Shen, Wenjuan Han
The Annual Conference of the European Chapter of the Association for Computational Linguistics (EACL)Under review. 2027
This paper proposes the zero-shot multimodal PAG-Agent framework for personalized music album generation with cross-modal aesthetic distillation, builds the ethical Personal-100 dataset, and designs the PA-Eval benchmark equipped with ACS and ASI metrics to quantify subjective aesthetic alignment, whose experiments show it surpasses all baselines with significant gains in aesthetic consistency and specificity and is validated by human evaluations.
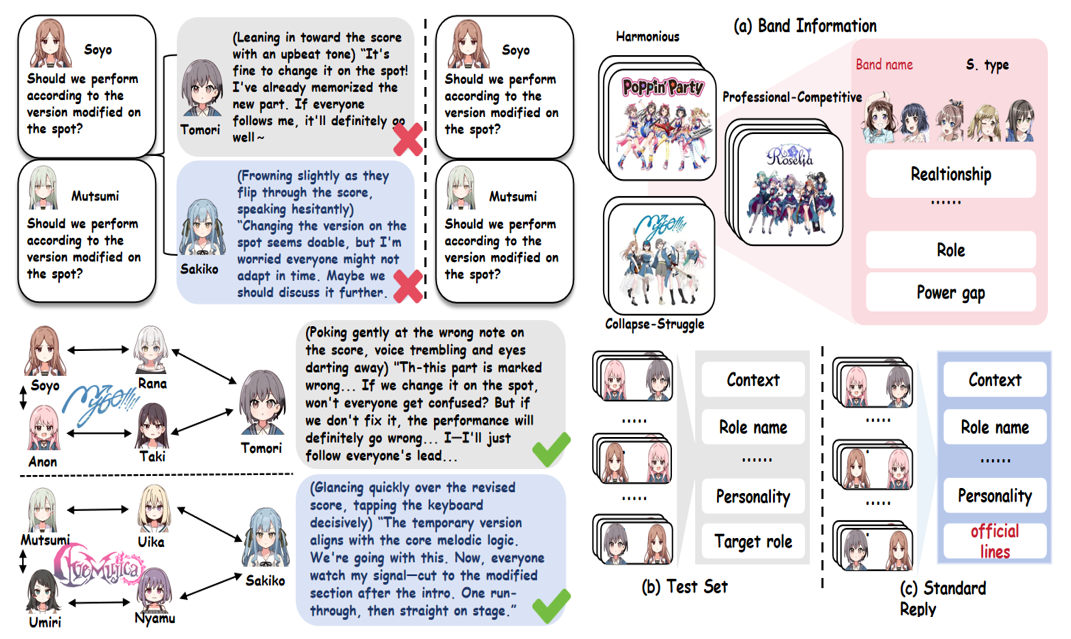
SxPxC: Transforming Multi-Agent Social Simulation from Isolated Personas to Socialized Intelligence via Structural Decoupling Multimodal
Yutong Shen, Yinqi Liu, Qin Yingzhi, Yaomin Wang, Hongda Sun, Qinghao Shao, Liyang Gao, Runzhuo Li, Zhi Zheng
Under ReviewUnder review. 2027
We propose the S×P×C tri-dimensional decoupling framework paired with Dual-Chain Inference to fix Structural OOC in multi-agent social simulation by elevating group social structure as top cognitive prior, and build the BanG-Struct benchmark to verify its superior structural adherence and dialogue quality over existing role-play baselines.
SxPxC: Transforming Multi-Agent Social Simulation from Isolated Personas to Socialized Intelligence via Structural Decoupling Multimodal
Yutong Shen, Yinqi Liu, Qin Yingzhi, Yaomin Wang, Hongda Sun, Qinghao Shao, Liyang Gao, Runzhuo Li, Zhi Zheng
Under ReviewUnder review. 2027
We propose the S×P×C tri-dimensional decoupling framework paired with Dual-Chain Inference to fix Structural OOC in multi-agent social simulation by elevating group social structure as top cognitive prior, and build the BanG-Struct benchmark to verify its superior structural adherence and dialogue quality over existing role-play baselines.
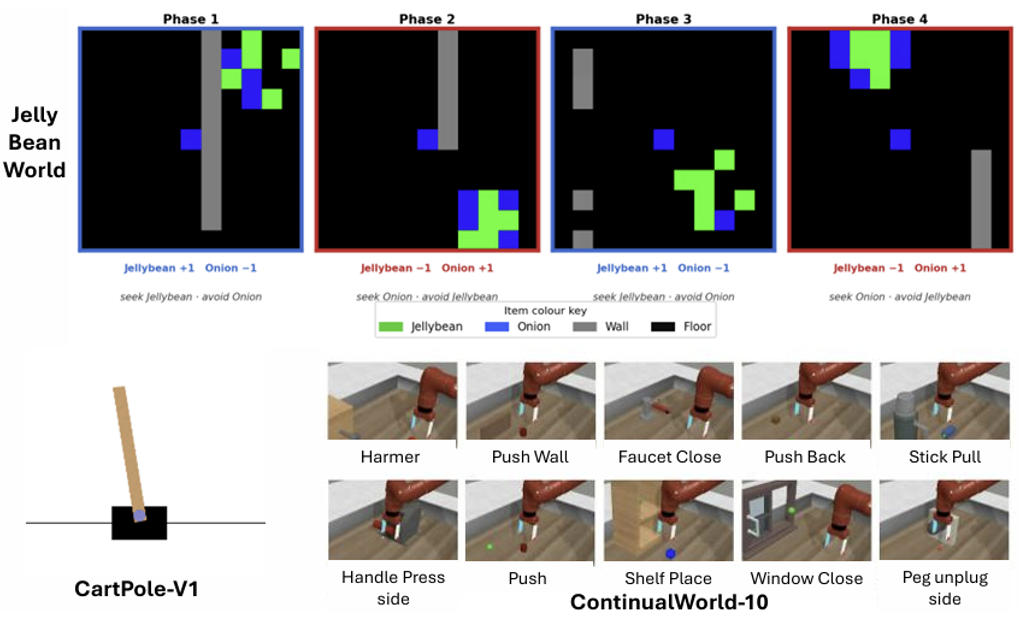
SPM: Surgical Plasticity Maintenance for Lifelong Reinforcement Learning in Big World Robotics
Heng Zhang, Pengsong Zhang, Qiyi Tong, Sheng Liu, Yutong Shen, Junjie Xie, Linfeng He, Arash Ajoudani
Under ReviewUnder review. 2027
We propose lightweight Surgical Plasticity Maintenance (SPM) for lifelong robotic RL, which monitors dead neuron ratio and activation rank to perform targeted dormant neuron reinitialization and adaptive per-layer learning rate scaling, retaining full learning capacity and beating standard baselines on multiple continual control benchmarks.
SPM: Surgical Plasticity Maintenance for Lifelong Reinforcement Learning in Big World Robotics
Heng Zhang, Pengsong Zhang, Qiyi Tong, Sheng Liu, Yutong Shen, Junjie Xie, Linfeng He, Arash Ajoudani
Under ReviewUnder review. 2027
We propose lightweight Surgical Plasticity Maintenance (SPM) for lifelong robotic RL, which monitors dead neuron ratio and activation rank to perform targeted dormant neuron reinitialization and adaptive per-layer learning rate scaling, retaining full learning capacity and beating standard baselines on multiple continual control benchmarks.
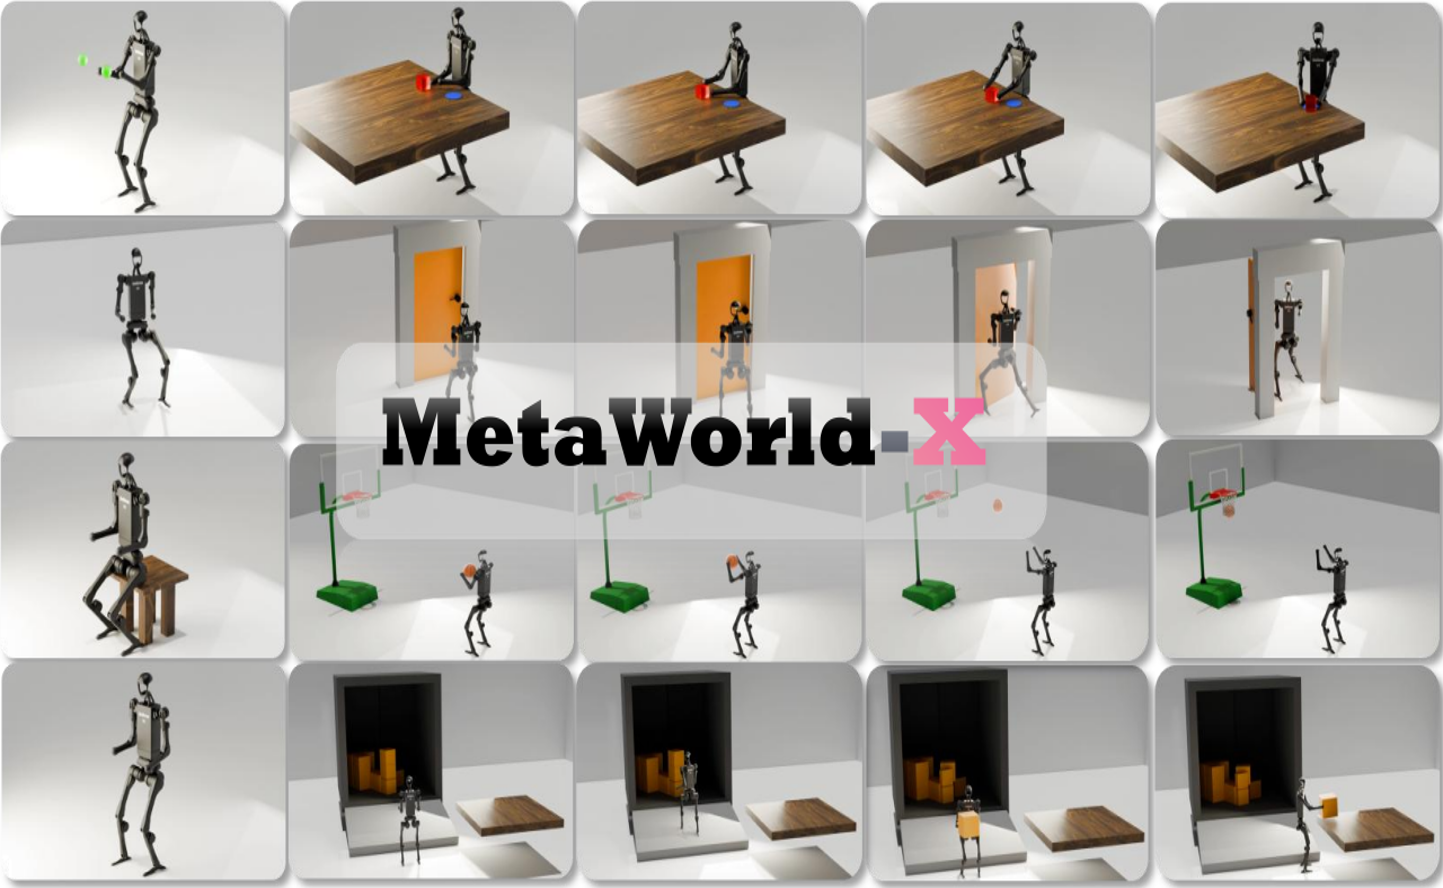
MetaWorld-X: Hierarchical World Modeling via Semantic-Prior Orchestrated Experts for Humanoid Loco-Manipulation Robotics
Yutong Shen*, Haidong Huang*, Heng Zhang, Penghui Liu, Jiashuo Luo, Shunqi Zhang, Chen Jiang, Chenguang Yang, Arash Ajoudani, Jianwei Zhang, Lei Zhang (* equal contribution)
Under ReviewUnder review. 2027
We propose a whole-body control framework for humanoid robots that mitigates cross-skill interference in high-DoF systems via Specialized Expert Policies (SEP), a VLM-supervised Intelligent Routing Mechanism (IRM), and latent dynamics model-based training-time optimization, achieving significant return improvements and faster convergence on HumanoidBench.
MetaWorld-X: Hierarchical World Modeling via Semantic-Prior Orchestrated Experts for Humanoid Loco-Manipulation Robotics
Yutong Shen*, Haidong Huang*, Heng Zhang, Penghui Liu, Jiashuo Luo, Shunqi Zhang, Chen Jiang, Chenguang Yang, Arash Ajoudani, Jianwei Zhang, Lei Zhang (* equal contribution)
Under ReviewUnder review. 2027
We propose a whole-body control framework for humanoid robots that mitigates cross-skill interference in high-DoF systems via Specialized Expert Policies (SEP), a VLM-supervised Intelligent Routing Mechanism (IRM), and latent dynamics model-based training-time optimization, achieving significant return improvements and faster convergence on HumanoidBench.
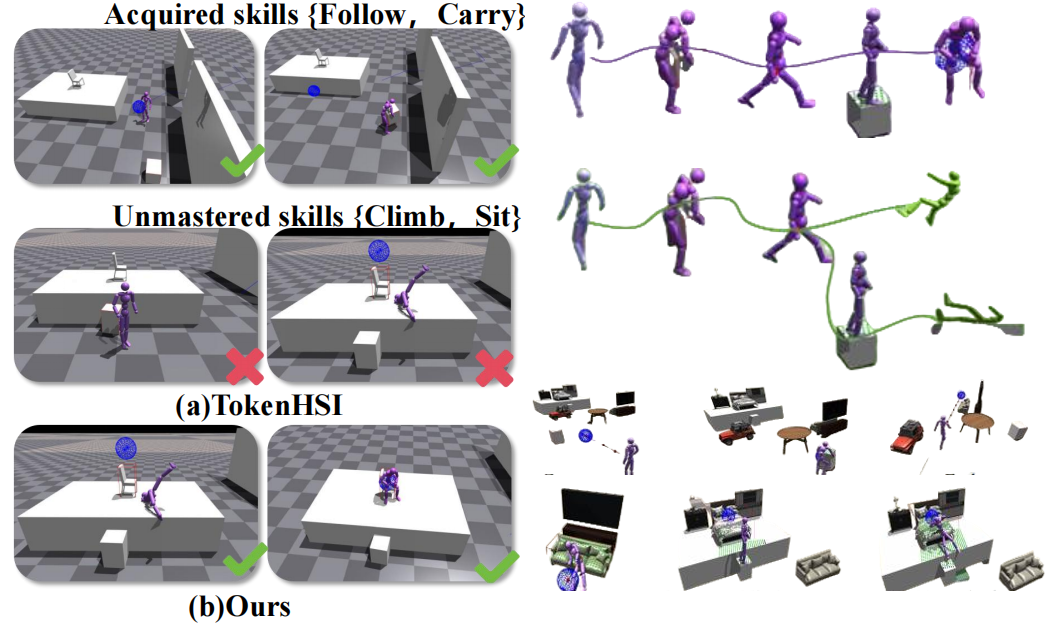
ALAS: Adaptive Long-Horizon Action Synthesis via Disentangled Environment and Self-State Representations Robotics
Yutong Shen*, Haidong Huang*, Lei Zhang, Penghui Liu, Yinqi Liu, Tongtong Feng (* equal contribution)
Under ReviewUnder review. 2027
This paper proposes a biologically inspired dual-stream disentangled framework decoupling environmental scene representations and robot self-state motor encodings, equipped with three adaptive feature fusion strategies and a staged progressive training pipeline, which achieves remarkable cross-environment and cross-skill generalization for long-horizon human-scene interaction tasks and outperforms existing state-of-the-art methods on self-designed benchmarks and HumanoidBench with higher subtask success rates and execution efficiency.
ALAS: Adaptive Long-Horizon Action Synthesis via Disentangled Environment and Self-State Representations Robotics
Yutong Shen*, Haidong Huang*, Lei Zhang, Penghui Liu, Yinqi Liu, Tongtong Feng (* equal contribution)
Under ReviewUnder review. 2027
This paper proposes a biologically inspired dual-stream disentangled framework decoupling environmental scene representations and robot self-state motor encodings, equipped with three adaptive feature fusion strategies and a staged progressive training pipeline, which achieves remarkable cross-environment and cross-skill generalization for long-horizon human-scene interaction tasks and outperforms existing state-of-the-art methods on self-designed benchmarks and HumanoidBench with higher subtask success rates and execution efficiency.
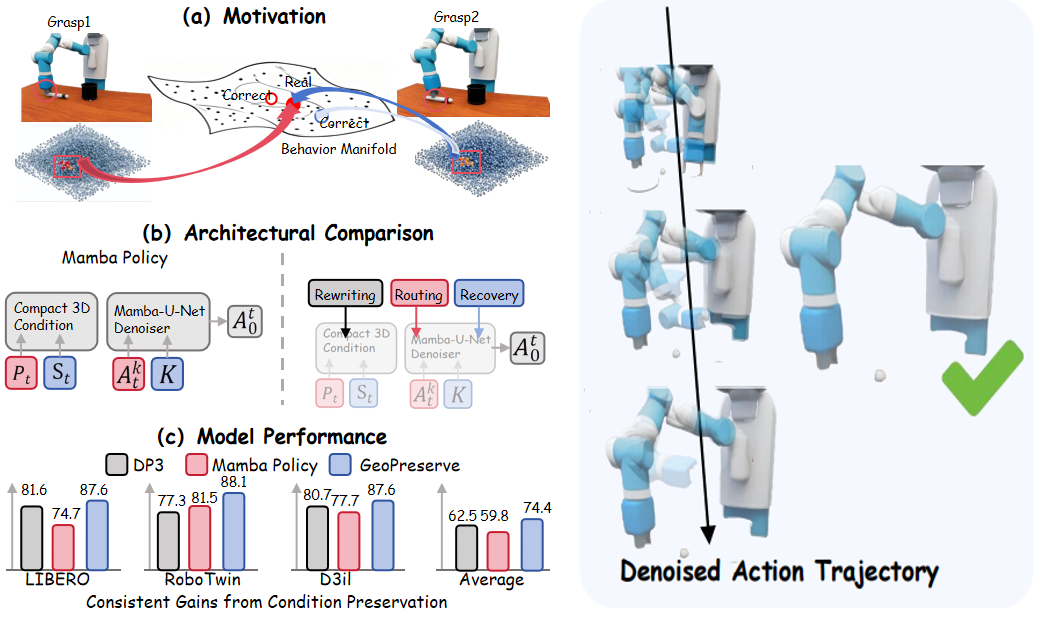
GeoPreserve: Condition-Preserving 3D Diffusion Policies for Contact-Sensitive Long-Horizon Manipulation Robotics
Haidong Huang*, Yutong Shen*, Xingwei Chen, Heng Zhang, Chenguang Yang, Haiyue Zhu, Jun Ma, Xiaocong Li (* equal contribution)
Under ReviewUnder review. 2027
This paper proposes a condition-preserving 3D diffusion robotic manipulation policy built on a three-stage Rewriting-Routing-Recovery pipeline, which addresses the issue of critical discriminative geometric information being lost during the compression of 3D observations in contact-sensitive long-horizon tasks, achieving consistent performance gains across multiple robotic manipulation benchmarks with only a tiny increase in model parameters.
GeoPreserve: Condition-Preserving 3D Diffusion Policies for Contact-Sensitive Long-Horizon Manipulation Robotics
Haidong Huang*, Yutong Shen*, Xingwei Chen, Heng Zhang, Chenguang Yang, Haiyue Zhu, Jun Ma, Xiaocong Li (* equal contribution)
Under ReviewUnder review. 2027
This paper proposes a condition-preserving 3D diffusion robotic manipulation policy built on a three-stage Rewriting-Routing-Recovery pipeline, which addresses the issue of critical discriminative geometric information being lost during the compression of 3D observations in contact-sensitive long-horizon tasks, achieving consistent performance gains across multiple robotic manipulation benchmarks with only a tiny increase in model parameters.
2026
FENAS: A Few-shot meta-Ensembling framework for efficient Neural Architecture Search with synergized zero-cost proxies Multimodal
Yifeng Mao, Yuze Feng, Yutong Shen, Penghui Liu, Liyang Gao, Zhixiang He
International Conference on Neural Information Processing (ICONIP) 2026
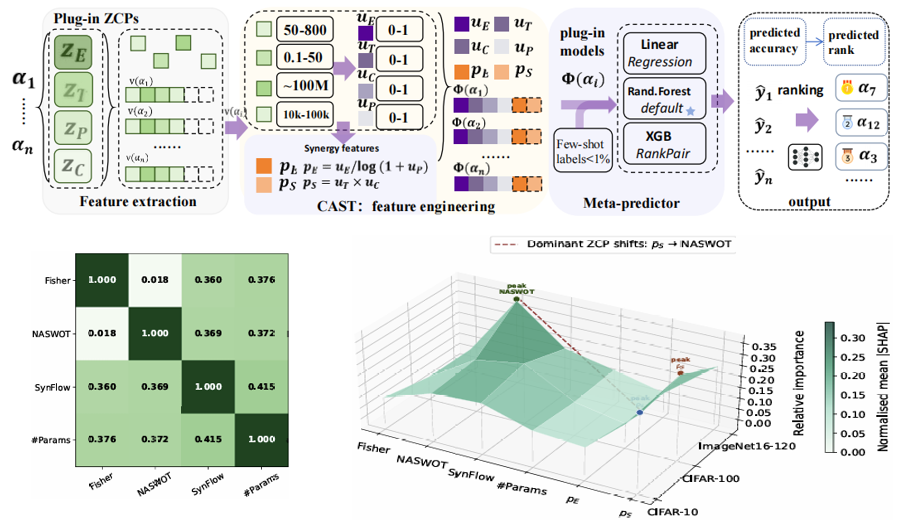
This paper proposes a topology-free few-shot meta-ensembling NAS framework equipped with the CAST feature transformation module that fuses four complementary zero-cost proxy physical features to realize accurate, stable, and ultra-efficient neural architecture performance prediction under extremely limited labeled architecture samples without complex graph topology encoding.
FENAS: A Few-shot meta-Ensembling framework for efficient Neural Architecture Search with synergized zero-cost proxies Multimodal
Yifeng Mao, Yuze Feng, Yutong Shen, Penghui Liu, Liyang Gao, Zhixiang He
International Conference on Neural Information Processing (ICONIP) 2026
This paper proposes a topology-free few-shot meta-ensembling NAS framework equipped with the CAST feature transformation module that fuses four complementary zero-cost proxy physical features to realize accurate, stable, and ultra-efficient neural architecture performance prediction under extremely limited labeled architecture samples without complex graph topology encoding.
Preserving Operator Intent Under Actuation Constraints: Teleoperation of Manipulators with Coupled Transmissions Robotics Oral
Xuhan Miao*, Zijin Han*, Yutong Shen, Haidong Huang, Shanliushui Gao, Xiaocong Li, Lei Zhang, Chenguang Yang (* equal contribution)
5th Sensorimotor-Augmented Teleoperation @ IROS 2026
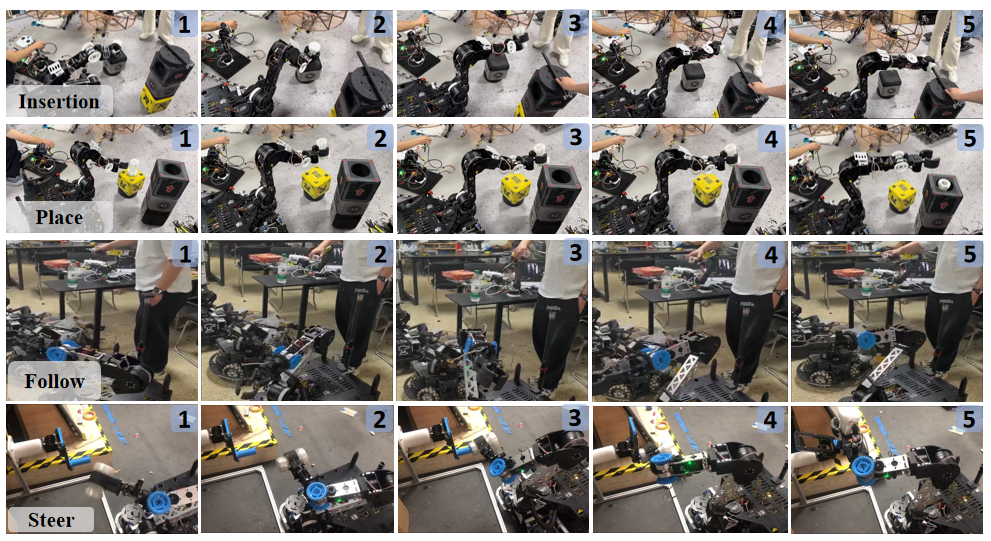
We proposes an actuator‑constraint‑aware master‑slave teleoperation method for manipulators with coupled transmissions to preserve the operator’s motion intent under gravitational loads and motor saturation. It reduces motion distortion and recovery transients via coordinated command projection in actuator space, continuous angle unwrapping and feasible‑reference updates, with its effectiveness validated by real‑robot experiments and ablation studies.
Preserving Operator Intent Under Actuation Constraints: Teleoperation of Manipulators with Coupled Transmissions Robotics Oral
Xuhan Miao*, Zijin Han*, Yutong Shen, Haidong Huang, Shanliushui Gao, Xiaocong Li, Lei Zhang, Chenguang Yang (* equal contribution)
5th Sensorimotor-Augmented Teleoperation @ IROS 2026
We proposes an actuator‑constraint‑aware master‑slave teleoperation method for manipulators with coupled transmissions to preserve the operator’s motion intent under gravitational loads and motor saturation. It reduces motion distortion and recovery transients via coordinated command projection in actuator space, continuous angle unwrapping and feasible‑reference updates, with its effectiveness validated by real‑robot experiments and ablation studies.
Detach: Cross-domain Learning for Long-Horizon Tasks via Mixture of Disentangled Experts Robotics
Yutong Shen, Hangxu Liu, Lei Zhang, Penghui Liu, Ruizhe Xia, Tongtong Feng
Life Long Agent @ ICLR 2026
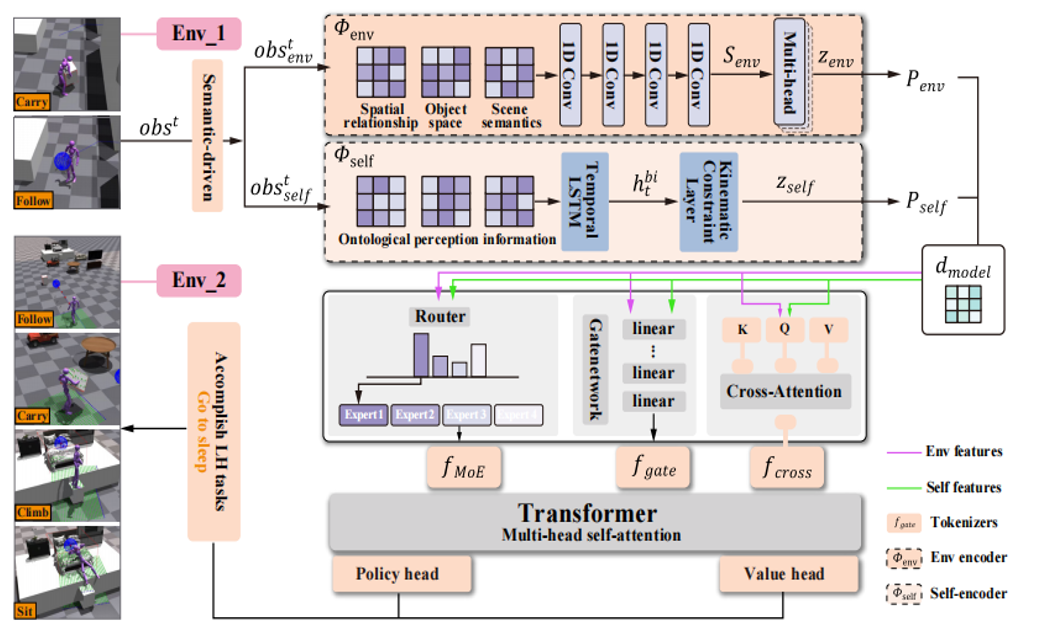
We propose a bio-inspired dual-stream disentanglement framework separating environment and self-state representations to enable cross-domain, cross-skill generalization for human-scene long-horizon tasks, boosting subtask success by 23% and execution efficiency by 29% over prior methods.
Detach: Cross-domain Learning for Long-Horizon Tasks via Mixture of Disentangled Experts Robotics
Yutong Shen, Hangxu Liu, Lei Zhang, Penghui Liu, Ruizhe Xia, Tongtong Feng
Life Long Agent @ ICLR 2026
We propose a bio-inspired dual-stream disentanglement framework separating environment and self-state representations to enable cross-domain, cross-skill generalization for human-scene long-horizon tasks, boosting subtask success by 23% and execution efficiency by 29% over prior methods.
MetaWorld: Skill Transfer and Composition in a Hierarchical World Model for Grounding High-Level Instructions Robotics
Yutong Shen, Hangxu Liu, Kailin Pei, Yinqi Liu, Ruizhe Xia, Tongtong Feng
ViSCALE @ CVPR 2026
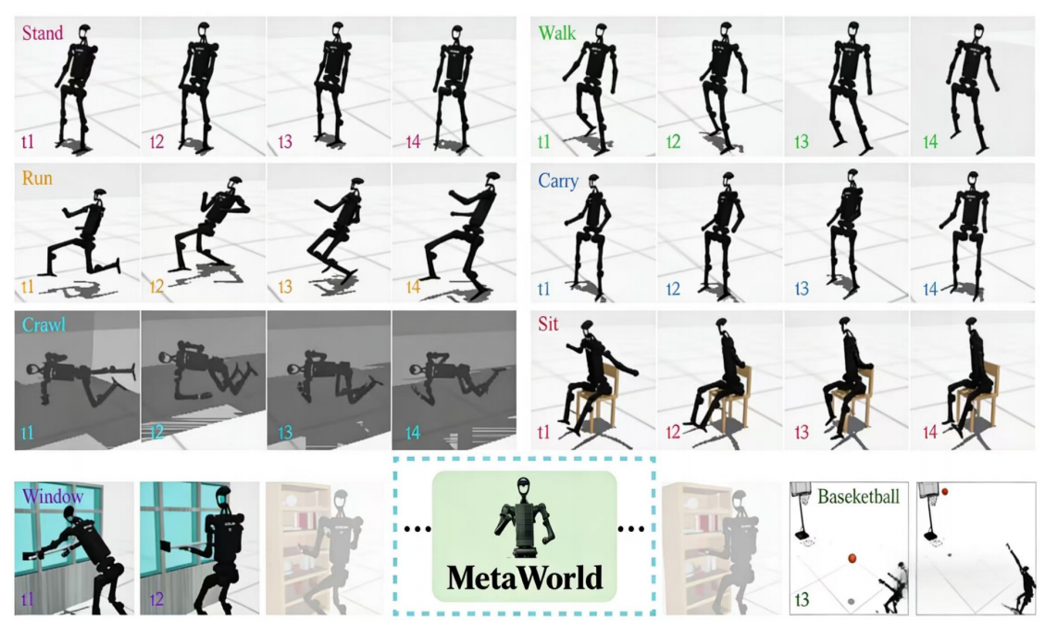
We present a hierarchical humanoid world model integrating VLM semantic planning, fused pre-trained motion expert priors and latent MPC dynamics, which resolves symbol grounding and sample inefficiency and surpasses TD-MPC2 & DreamerV3 on HumanoidBench with greatly improved average rewards and task success rates.
MetaWorld: Skill Transfer and Composition in a Hierarchical World Model for Grounding High-Level Instructions Robotics
Yutong Shen, Hangxu Liu, Kailin Pei, Yinqi Liu, Ruizhe Xia, Tongtong Feng
ViSCALE @ CVPR 2026
We present a hierarchical humanoid world model integrating VLM semantic planning, fused pre-trained motion expert priors and latent MPC dynamics, which resolves symbol grounding and sample inefficiency and surpasses TD-MPC2 & DreamerV3 on HumanoidBench with greatly improved average rewards and task success rates.
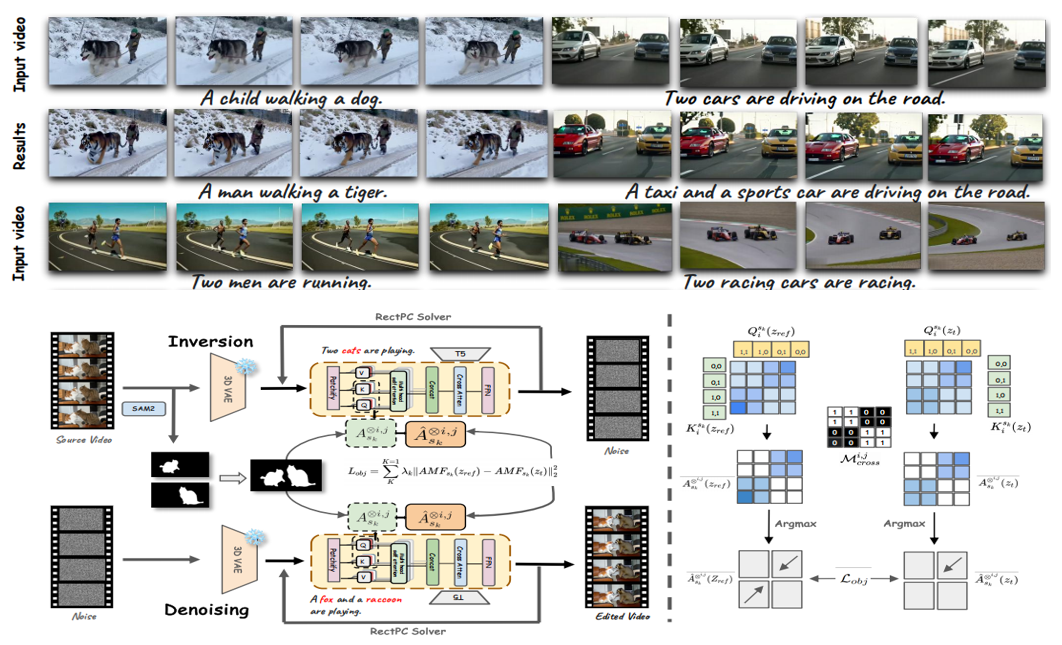
MultiMotion: Multi Subject Video Motion Transfer via Video Diffusion Transformer Computer Vision
Penghui Liu, Jiangshan Wang, Yutong Shen, Shanhui Mo, Chenyang Qi, Yue Ma
AAAI Conference on Artificial Intelligence(AAAI) 2026
We propose MultiMotion, a DiT-based multi-object motion transfer framework with mask-aware AMF and RectPC solver, validated on our new MultiMotionEval benchmark with superior metrics.
MultiMotion: Multi Subject Video Motion Transfer via Video Diffusion Transformer Computer Vision
Penghui Liu, Jiangshan Wang, Yutong Shen, Shanhui Mo, Chenyang Qi, Yue Ma
AAAI Conference on Artificial Intelligence(AAAI) 2026
We propose MultiMotion, a DiT-based multi-object motion transfer framework with mask-aware AMF and RectPC solver, validated on our new MultiMotionEval benchmark with superior metrics.
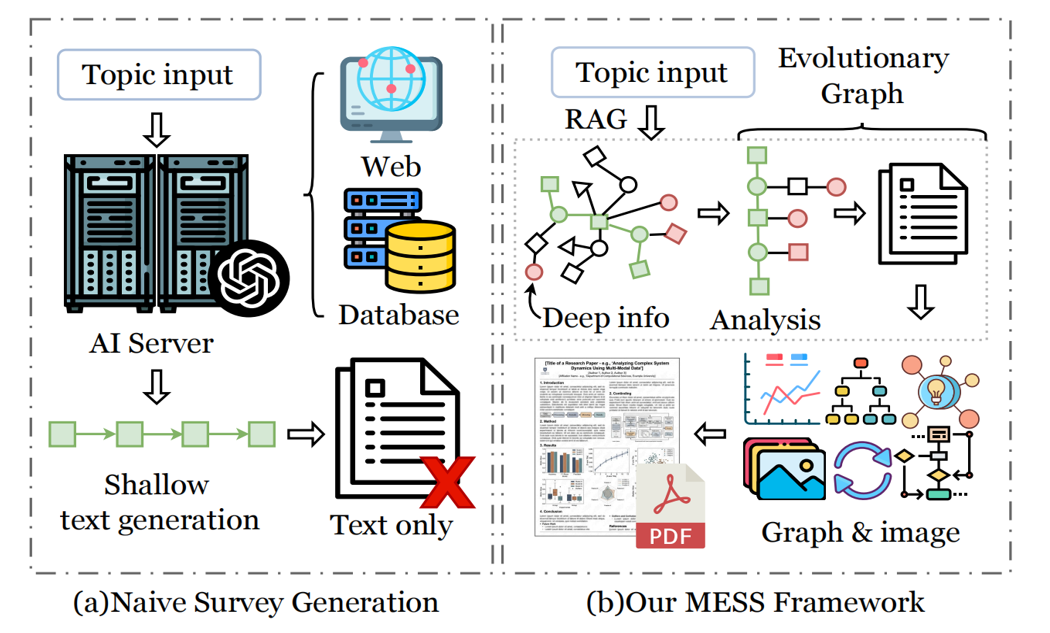
MESS: Deep Reasoning and Multimodal Agentic Framework for Evolutionary Survey Synthesis Multimodal
Yinqi Liu, Yongkang Zhang, Yueqi Zhu, Ruyi Feng, Yutong Shen, Yidong Wang, Cunxiang Wang, Yangning Li, Yinghui Li
ACM International Conference on Multimedia (ACM MM) 2026
We propose an agentic multimodal framework with limitation-driven recursive retrieval to build causal literature evolutionary chains and a vision-critic loop for hallucination-free academic diagram generation, which outperforms all baselines on our curated 100-topic dataset with new logical and visual evaluation metrics.
MESS: Deep Reasoning and Multimodal Agentic Framework for Evolutionary Survey Synthesis Multimodal
Yinqi Liu, Yongkang Zhang, Yueqi Zhu, Ruyi Feng, Yutong Shen, Yidong Wang, Cunxiang Wang, Yangning Li, Yinghui Li
ACM International Conference on Multimedia (ACM MM) 2026
We propose an agentic multimodal framework with limitation-driven recursive retrieval to build causal literature evolutionary chains and a vision-critic loop for hallucination-free academic diagram generation, which outperforms all baselines on our curated 100-topic dataset with new logical and visual evaluation metrics.
2025
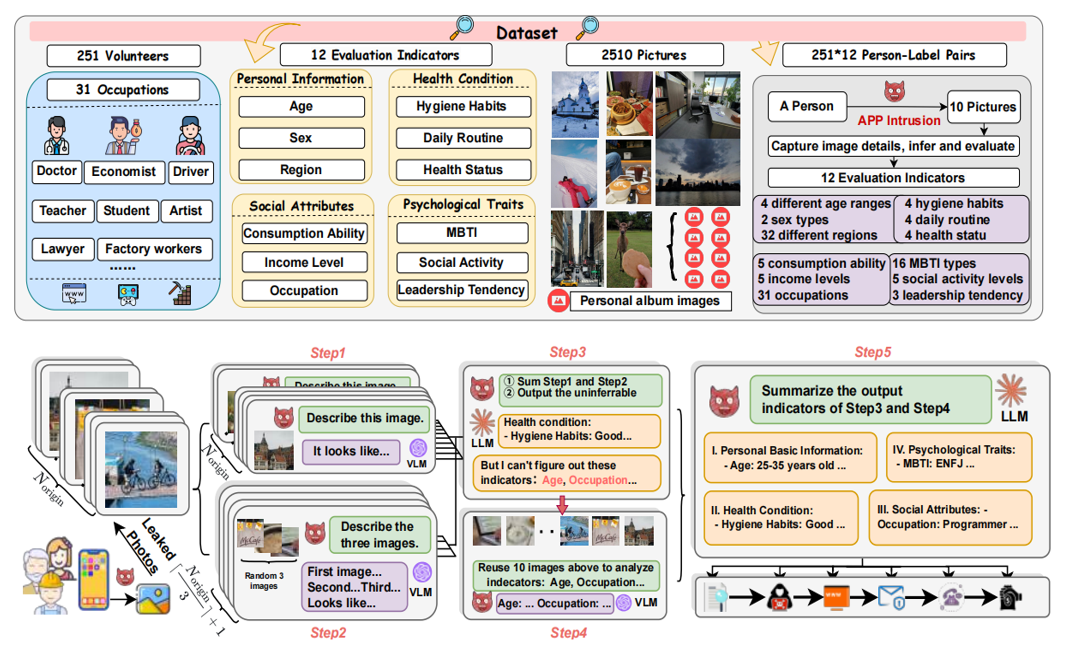
The Eye of Sherlock Holmes: Uncovering User Private Attribute Profiling via Vision-Language Model Agentic Framework Multimodal
Feiran Liu, Yuzhe Zhang, Xinyi Huang, Yinan Peng, Xinfeng Li, Lixu Wang, Yutong Shen, Ranjie Duan, Simeng Qin, Xiaojun Jia, Qingsong Wen, Wei Dong
ACM International Conference on Multimedia (ACM MM) 2025
We uncover the privacy risk of multi-image user private attribute profiling, build the PAPI annotated dataset and propose HolmesEye, a VLM-LLM hybrid agentic framework with multi-stage cross-image reasoning that outperforms all baselines and human evaluators on comprehensive privacy attribute prediction tasks.
The Eye of Sherlock Holmes: Uncovering User Private Attribute Profiling via Vision-Language Model Agentic Framework Multimodal
Feiran Liu, Yuzhe Zhang, Xinyi Huang, Yinan Peng, Xinfeng Li, Lixu Wang, Yutong Shen, Ranjie Duan, Simeng Qin, Xiaojun Jia, Qingsong Wen, Wei Dong
ACM International Conference on Multimedia (ACM MM) 2025
We uncover the privacy risk of multi-image user private attribute profiling, build the PAPI annotated dataset and propose HolmesEye, a VLM-LLM hybrid agentic framework with multi-stage cross-image reasoning that outperforms all baselines and human evaluators on comprehensive privacy attribute prediction tasks.